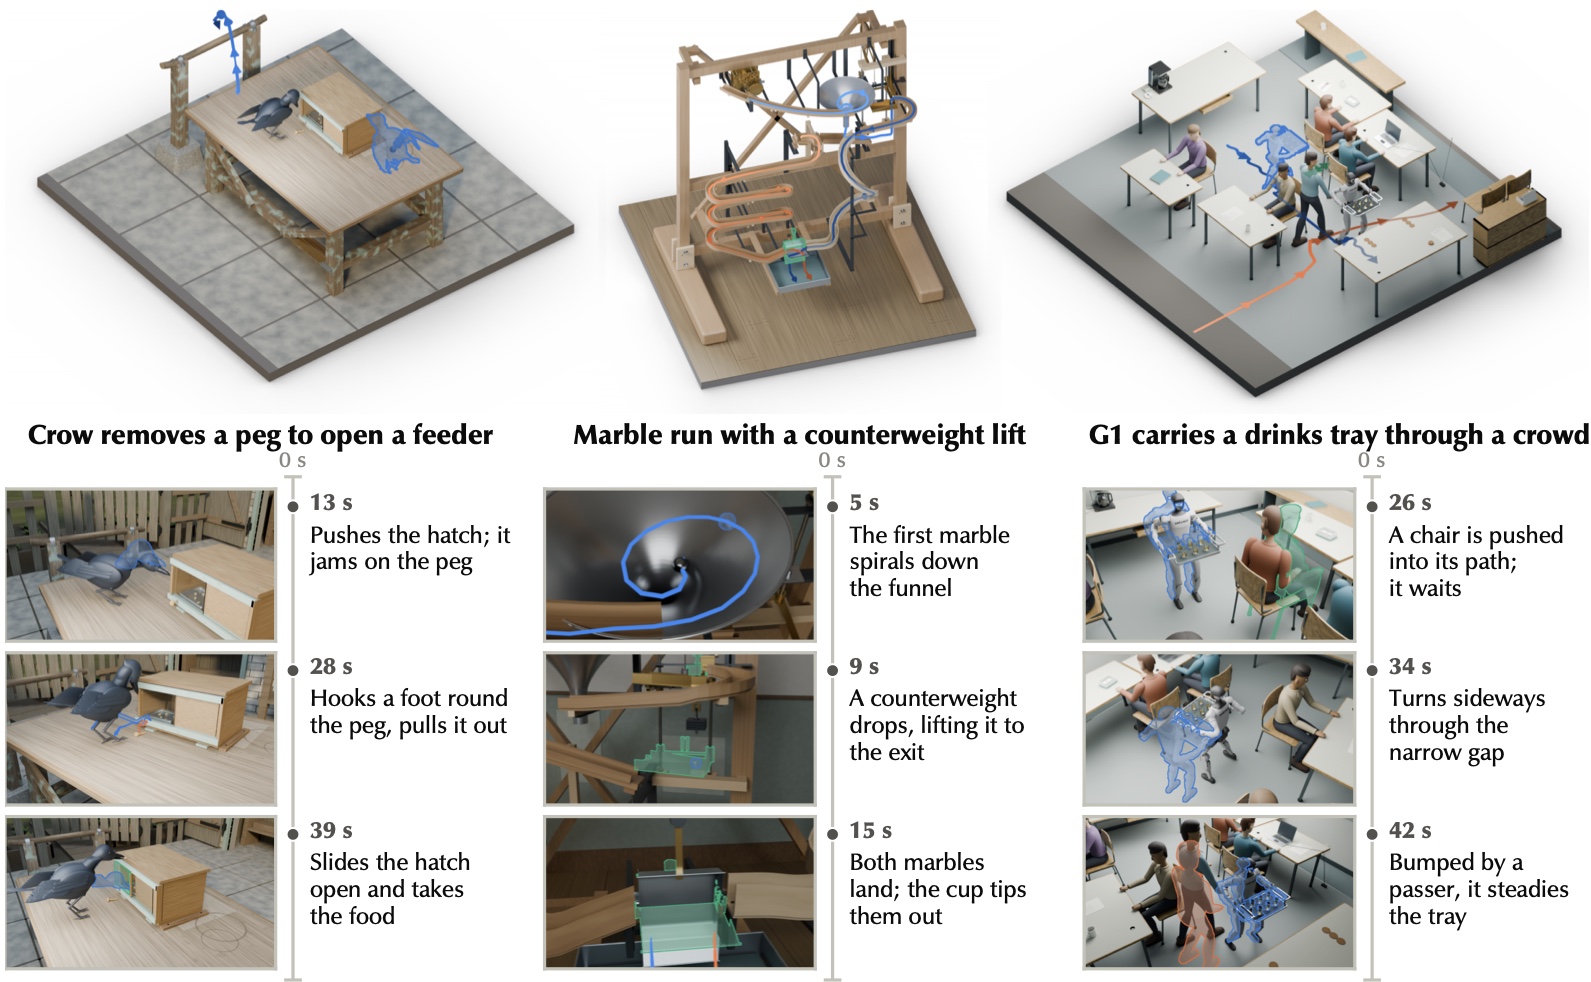
DyCraft: An Agentic System for Long-Horizon 4D Scene Generation
arXiv 2026

An agentic system that generates minute-long, physically plausible 4D scenes from text by planning a 3D storyboard of verified key poses and authoring motion between them.
I am an undergraduate student in Information and Computing Science at Peking University (graduating June 2027). I want robots to learn from 4D worlds that are physically correct, not just visually realistic, so I treat geometry, articulation, and dynamics as first-class targets when reconstructing or generating the world.
From the real world, I reconstruct simulation-ready articulated objects from a free-moving monocular RGB-D video (FreeArtGS, CVPR 2026) and build physics-aware digital twins for zero-shot real-to-sim-to-real policy transfer (TwinAligner). From imagination, I build agentic systems that generate minute-long, physically plausible 4D scenes from text (DyCraft). My goal is to make such worlds a scalable source of training data, simulation, and evaluation for robot learning. Building DyCraft also showed me that current multimodal LLMs are still poor at understanding 4D information from video, a gap I am interested in studying.

arXiv 2026
An agentic system that generates minute-long, physically plausible 4D scenes from text by planning a 3D storyboard of verified key poses and authoring motion between them.

CVPR 2026
Reconstructing articulated objects from a free-moving monocular RGB-D video through part segmentation, joint estimation, and Gaussian splatting.

arXiv 2025
Bridging visual and dynamic real-to-sim gaps to enable physics-aware simulation and zero-shot transfer for robotic manipulation.
* Equal contribution.
B.S. in Information and Computing Science
Expected graduation: June 2027 · GPA: 3.725/4.0 (28/107)
Relevant coursework: Machine Learning, Computer Vision, Data Structures.
Supervised by Prof. Hao Dong. Working on bridging the sim-to-real gap, 3D asset reconstruction, and data generation.
Reviewer: IEEE Robotics and Automation Letters (RA-L)
Feel free to get in touch about research, collaboration, or shared interests.

